Why a single power rating is not enough
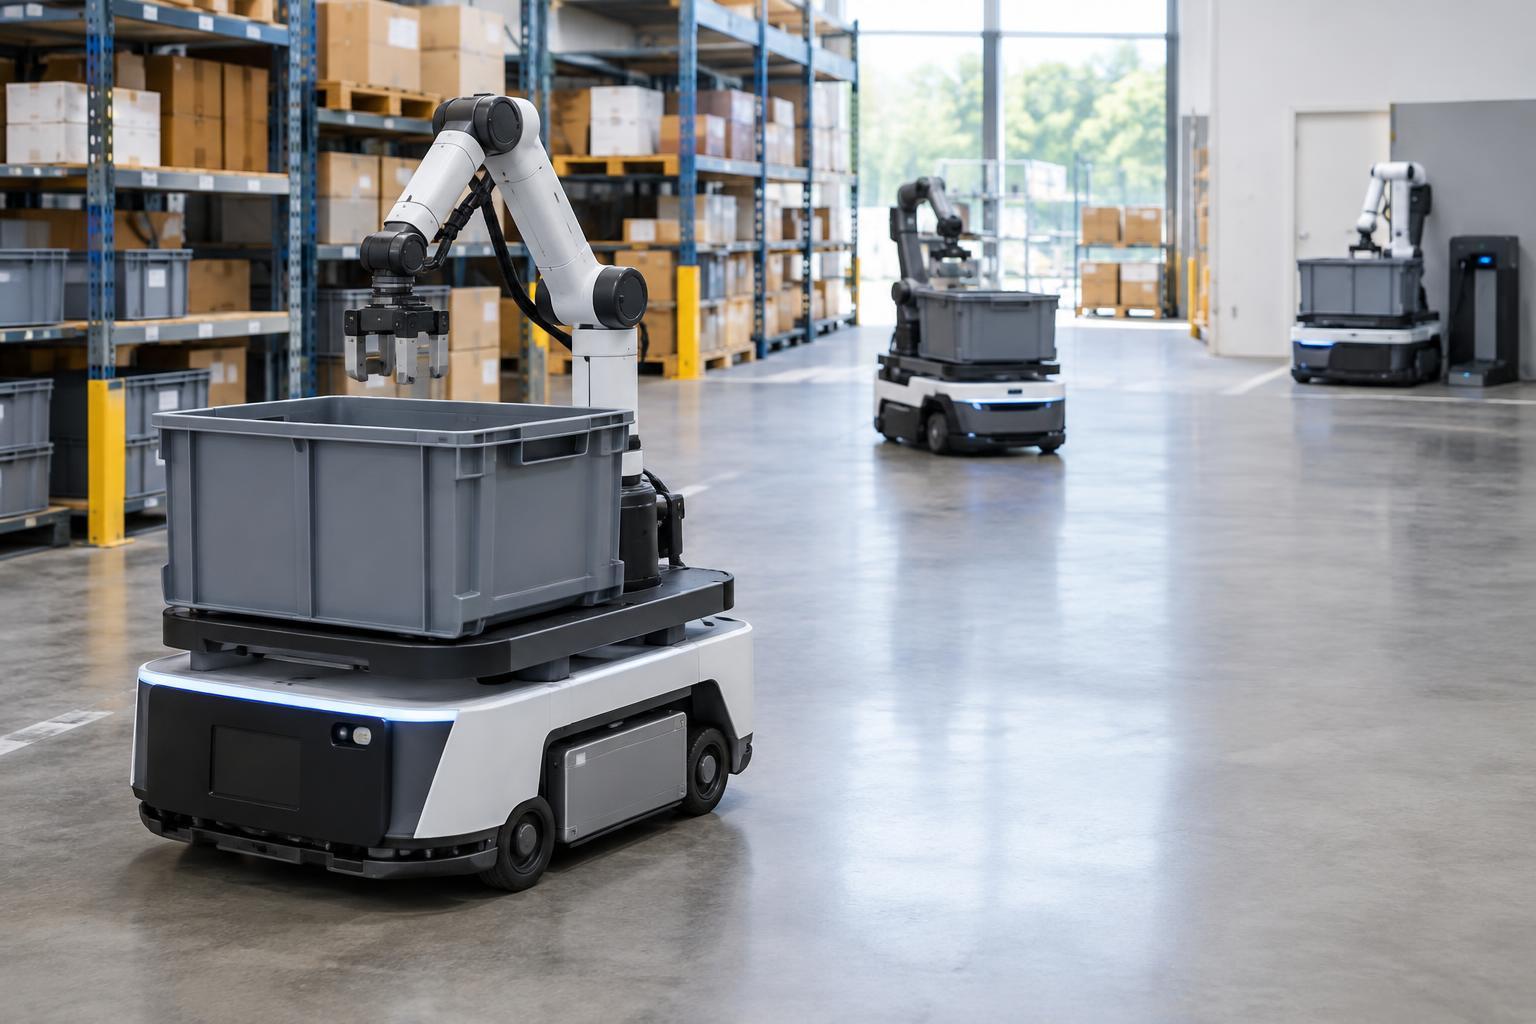
A robot’s battery runtime depends on what it does between charges, not just how large its battery is. A mobile robot might drive to a destination, lift an object, wait for a door, deliver the object and return. Each part of that cycle can draw a different amount of power. Dividing battery capacity by a motor’s rated power therefore gives a poor estimate of how long the robot can complete useful work.
Start by defining the work cycle you want to measure. For a cleaning robot, that might be one hour that includes driving, scrubbing and waiting. For a delivery robot, it might be one complete trip and return. Include tasks that are easy to overlook: sensing, onboard computing, wireless communication and time spent stationary but switched on. The goal is to represent a typical operating pattern rather than the robot’s most demanding moment.
Calculate energy use for each part of the cycle
Battery capacity is commonly stated in watt-hours (Wh), while power draw is stated in watts (W). To estimate the energy used by an activity, multiply its average power in watts by its duration in hours. Add the results for every activity in the cycle. If a manufacturer gives capacity only in amp-hours, you also need an appropriate battery voltage to estimate watt-hours; amp-hours alone are not a measure of energy.
Consider a hypothetical robot with a one-hour cycle: it travels for 20 minutes at an average of 80 W, performs its main task for 15 minutes at 120 W, and spends 25 minutes waiting at 20 W. Travel uses about 27 Wh, active work uses 30 Wh, and waiting uses about 8 Wh. The full cycle uses roughly 65 Wh. These are illustrative figures, not typical values for all robots.
Use average power for each activity rather than adding together the maximum ratings of every component. Motors may briefly draw much more power when starting or lifting, but a short peak does not last for the entire task. If a component runs throughout the cycle, such as a computer or sensor, make sure its draw is included in each mode or added separately—not counted twice.
Use the battery capacity you can actually spend
A battery’s stated capacity is not always the energy available for the planned work. A robot may need to stop at a chosen charge level so it can return to a dock, avoid an unplanned shutdown or leave room for variation between trips. Battery condition and temperature can also affect usable capacity. Treat the reserve as part of the estimate, not as an afterthought.
Suppose the example robot has a 200 Wh battery and you plan to use no more than 80% of its stated capacity before recharging. That leaves 160 Wh for work. Dividing 160 Wh by 65 Wh per one-hour cycle suggests about 2.5 hours of operation under the assumed pattern. If the job requires whole trips that cannot be interrupted, plan around the number of complete cycles the robot can finish, rather than relying on a fraction of a cycle.
Check how real tasks change the estimate
The calculation is a starting point because the mix of activities can shift. More stops and starts, heavier loads, slopes or rough flooring may raise travel energy use. Longer waits can lower average power draw while reducing the amount of useful work completed per hour. A task that keeps a tool running longer may have the opposite effect. Battery performance may also change as the pack ages.
A practical way to refine the estimate is to record the battery energy or charge used over several representative cycles, alongside the time spent in each activity. Compare an ordinary cycle with a demanding one. If the robot reports only a battery percentage, that can still help reveal which tasks consume charge quickly, though it is less precise than an energy reading. Recalculate when the route, payload, tool settings or work schedule changes.
Separate runtime from time available for work
Runtime describes how long the robot can operate before it needs to recharge. It does not tell you how much of a shift it can spend working. A robot that operates for two hours but then needs to travel to a dock and charge will have less time available for tasks. Queues at a shared charger or a human-assisted battery swap may add further downtime.
For planning, write down three figures: energy used per complete work cycle, the number of cycles possible within your chosen battery reserve, and the time needed before the robot can start again. This makes it easier to compare schedules, routes or battery options without mistaking a best-case runtime figure for a reliable work plan.