The difference between moving and knowing where to move
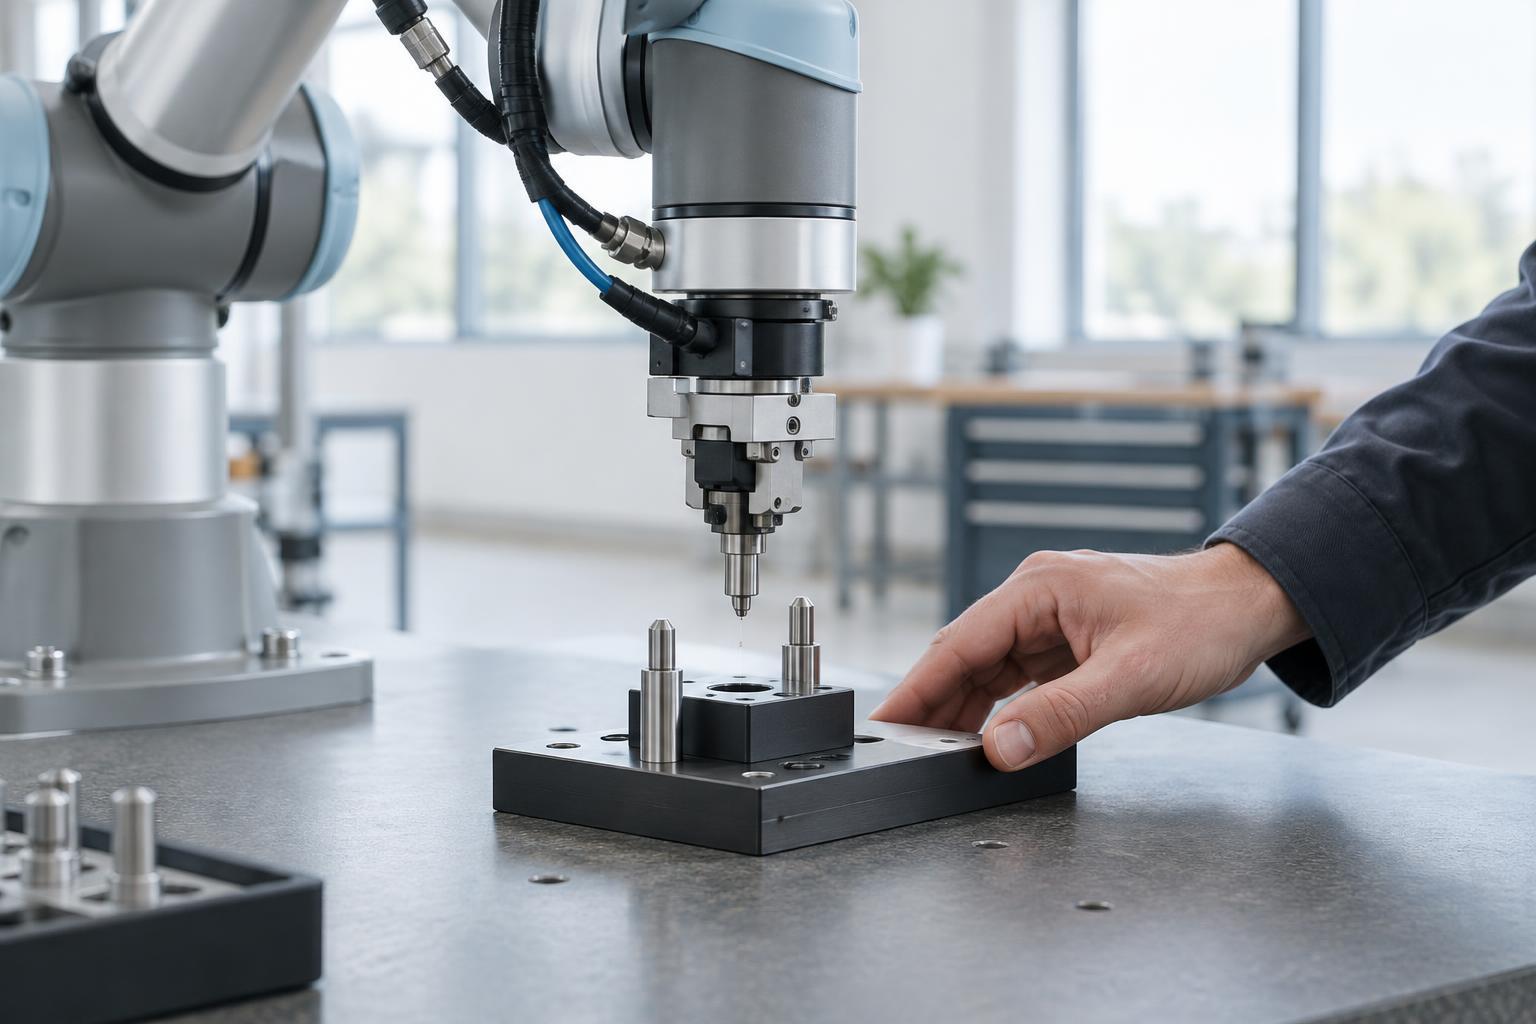
Imagine a robot arm that picks up a cup from the same spot every morning. Its motors may repeat the same motion with impressive consistency. But if the camera above the table shifts slightly, the robot may now estimate the cup’s position incorrectly. It can execute its planned movement faithfully and still reach beside the cup. The problem is not necessarily the movement; it is the relationship between what the robot measures and where things actually are.
Calibration establishes that relationship. Depending on the machine, it might connect a camera image to positions on a work surface, establish the starting position of a joint, or account for the size of a tool attached to an arm. A controller then uses those relationships to turn measurements and commands into motion. Calibration does not make a robot universally accurate: it gives the robot a usable reference within the conditions for which the setup was checked.
What a robot needs to line up
Robots often describe positions using coordinate frames: agreed-upon ways to measure location and orientation relative to something. An arm might track the position of its base, its tool and the object it wants to handle. A camera has its own view of the scene. To pick up an object detected in an image, the system needs to know how that camera view relates to the arm and its workspace. If the camera is mounted at a different angle than the robot expects, an object seen clearly may still be assigned the wrong reachable position.
Other robots have different alignment needs. A wheeled robot may estimate travel from wheel rotation, but that estimate depends partly on assumptions about wheel size and contact with the floor. A gripper may need its effective center adjusted after its fingers are changed. A robot with movable joints may need to establish a known starting position when it powers on. These examples share a principle: a sensor reading becomes useful for action only when the robot can interpret what the reading means in its physical setup.
Why a good calibration can stop being good
Calibration is not always a one-time task. A camera mount can be bumped, a tool can be replaced, or a robot can be moved to another table. Wear and temperature changes may also affect some setups, though their significance depends on the machine and the precision the task requires. A small change that makes no practical difference for moving a large box could matter when placing a tiny component.
It helps to distinguish calibration from feedback. Feedback lets a robot compare what is happening with what it intended to happen and adjust its behavior. Calibration helps the robot interpret that feedback correctly. A camera-guided robot, for example, may keep adjusting toward an object it sees. If its camera-to-arm alignment is wrong, those adjustments can still lead it to the wrong place. More frequent corrections do not automatically fix an incorrect reference.
Warning signs can include repeated misses in the same direction, results that change after a tool swap, or a robot that works in one part of its workspace but not another. Such symptoms do not prove calibration is the cause: lighting, loose parts, slipping objects and software settings can produce similar results. They do, however, offer a reason to check the setup rather than simply asking the robot to repeat the task.
A practical way to think about checking alignment
Start with a repeatable test that resembles the real task. For a camera-guided pick, that might mean placing an object at several known locations and observing whether the robot reaches the intended points. Checking only one spot can hide a problem that becomes obvious farther away. Record the setup conditions that matter, such as camera position, attached tool and work-surface location, so a later check can be compared with the earlier one.
When a check fails, look for physical changes before altering software values. Confirm that mounts and tools are in their expected positions, then follow the machine maker’s procedure for establishing its reference points or recalibrating its sensors. Keep people clear of moving equipment and use the appropriate shutdown procedure before making physical adjustments. Finally, run the repeatable test again. The goal is not to chase a perfect number in isolation; it is to verify that the robot’s measurements remain reliable enough for the job it actually performs.